ModelBriefs · DeepSeek-V4-Flash · Graphics · Seedream-4.0
← Labs / 01
Research lab5 papers · 2022–2024
embodied AImanipulationgeneralist agents
Official publication archive↗Google DeepMind Robotics
Sustained primary work on robot foundation models, large-scale real-world data and generalist manipulation.
No.Paper · what it does and showsIndustry contribution
01
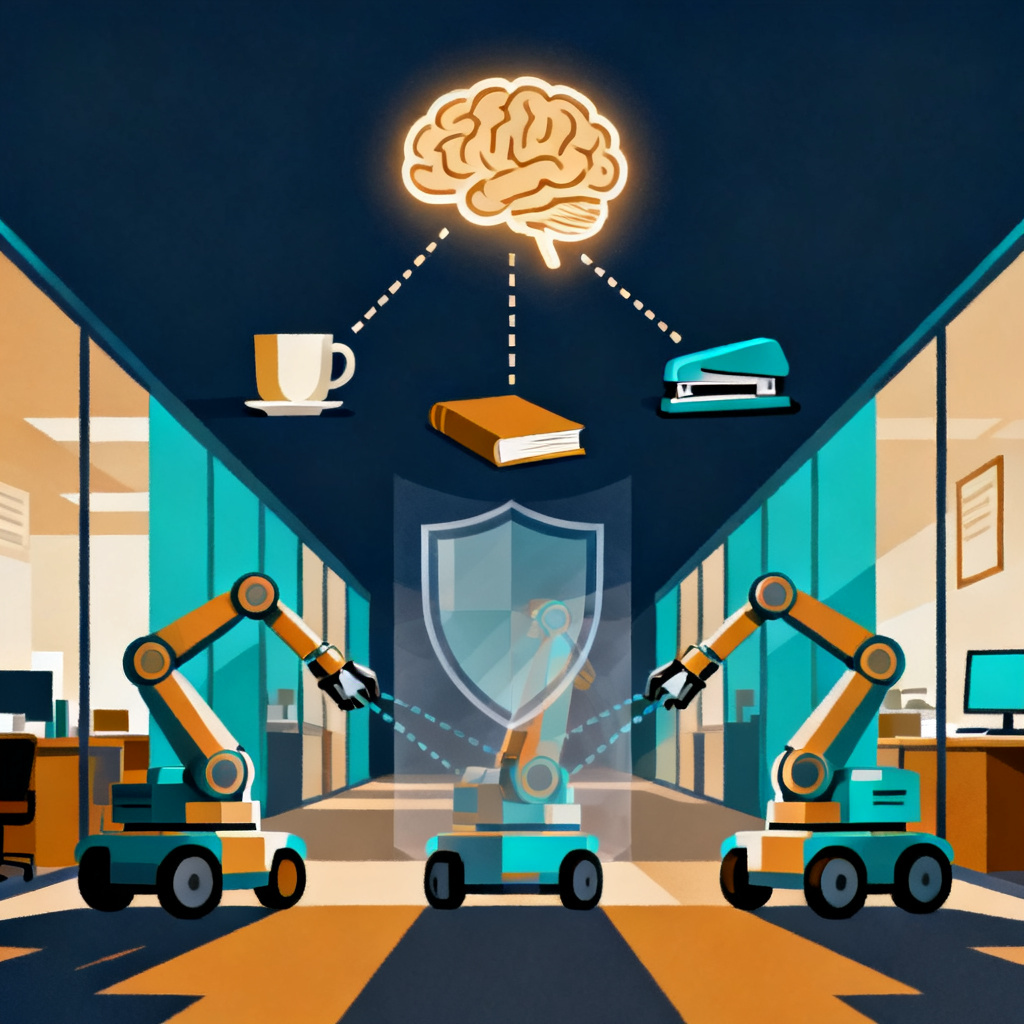
AutoRT: Embodied Foundation Models for Large Scale Orchestration2024 ↗
Uses an LLM to propose diverse tasks for fleets of mobile manipulators, filters every proposal through a safety layer, and collects the resulting real-world demonstrations in offices with minimal human supervision.
Established the fleet-scale, LLM-directed collection loop and safety filtering pattern industry now uses to gather large robot datasets without scripting each task by hand.
02
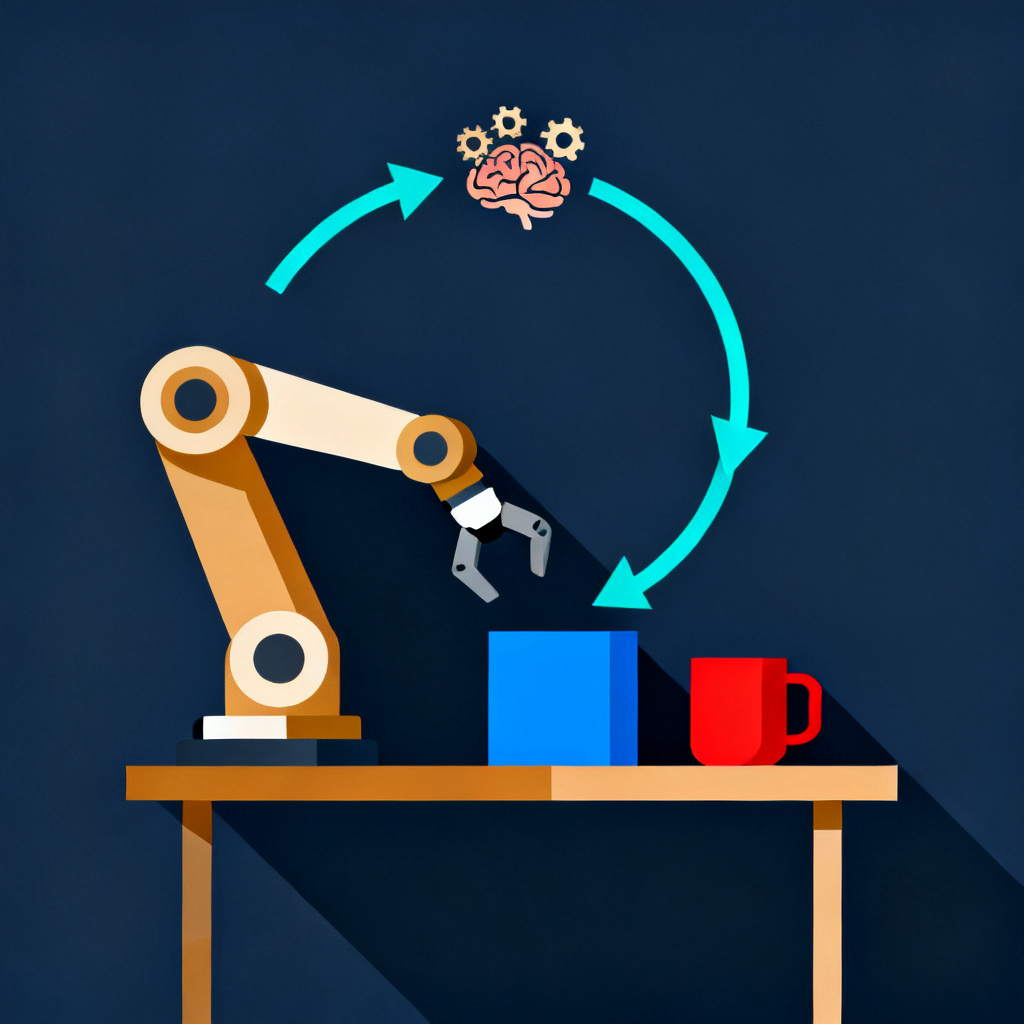
RoboCat: A Self-Improving Foundation Agent for Robotic Manipulation2023 ↗
A generalist agent that adapts to new tasks and new robot embodiments from roughly 100 demonstrations, then generates its own training data to improve across successive tasks.
Showed self-generated data can compound robot skill learning, the basis for the self-improvement loops robot-model teams now use to cut cost per new task.
03
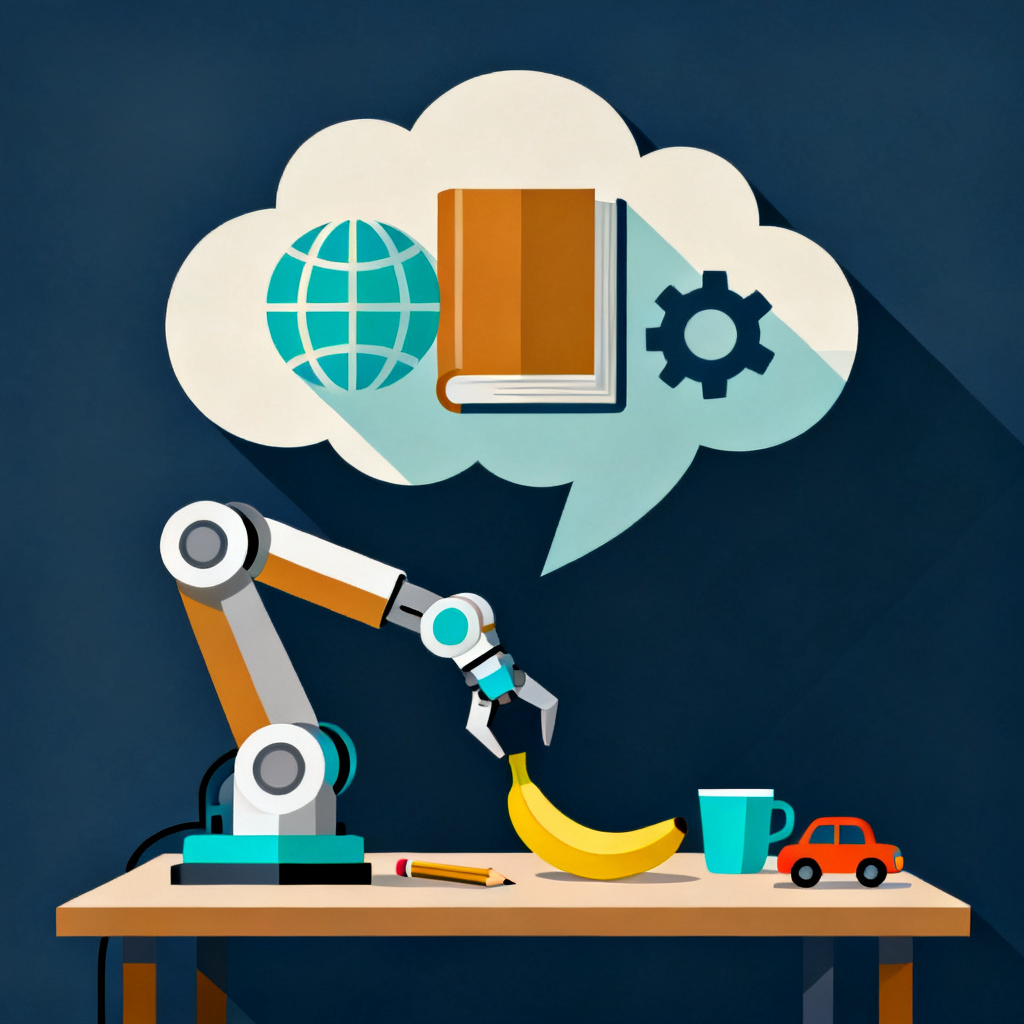
RT-2: Vision-Language-Action Models Transfer Web Knowledge to Robotic Control2023 ↗
Co-fine-tunes a web-scale vision-language model on robot trajectories so the resulting vision-language-action model inherits internet knowledge and generalizes to unseen objects and instructions.
Proved web pretraining transfers to physical control, which is why almost every commercial robot foundation model now starts from a pretrained VLM.
04
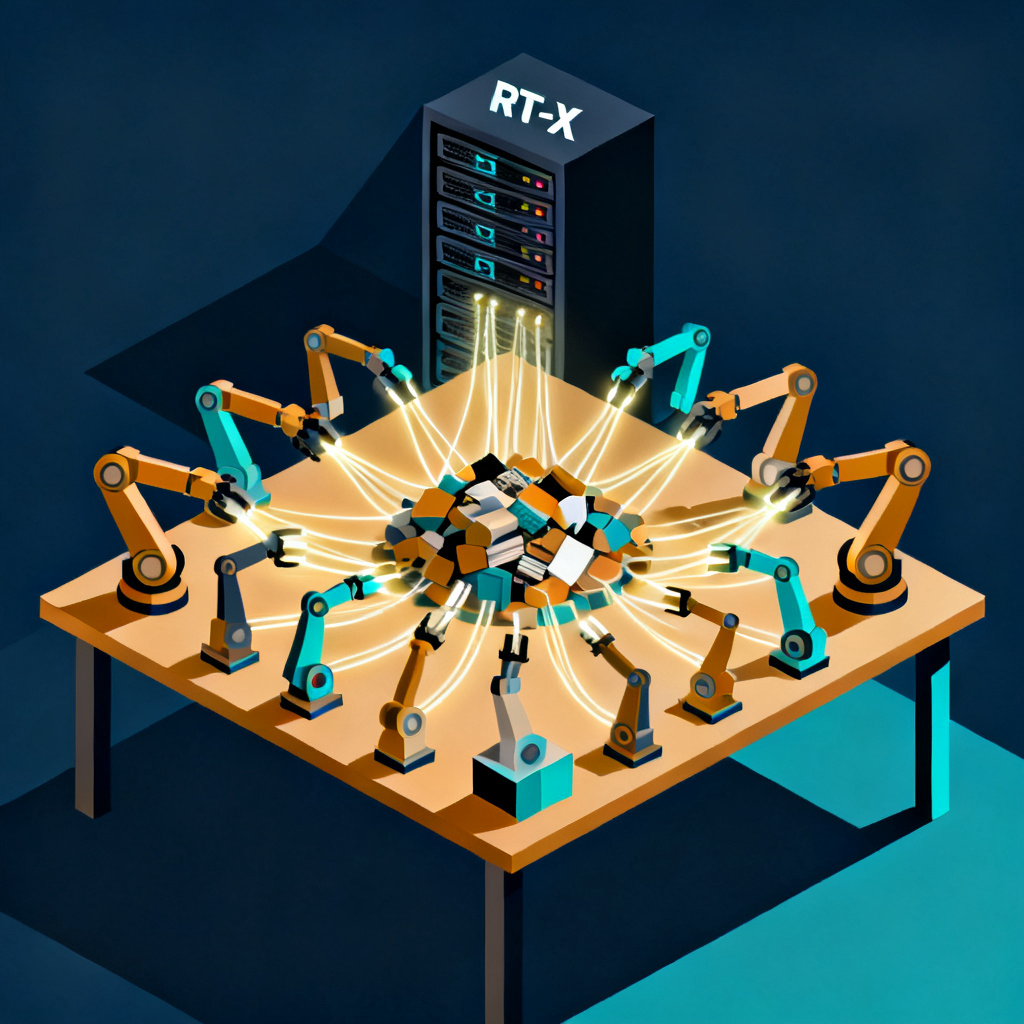
Open X-Embodiment: Robotic Learning Datasets and RT-X Models2023 ↗
Assembles more than one million trajectories from 22 robot embodiments into a single dataset and shows RT-X policies trained across them gain positive transfer.
Gave industry a shared multi-robot corpus plus evidence that cross-embodiment data helps, shaping how teams now mix data across heterogeneous robot fleets.
05
RT-1: Robotics Transformer for Real-World Control at Scale2022 ↗
A transformer policy trained on about 130,000 real robot episodes that maps camera images and natural-language instructions to discretized actions across hundreds of tasks at high control rates.
The first widely replicated evidence that one large policy can replace per-task controllers, making it the architectural baseline for today’s robot-learning stacks.