Illustration brief the model wrote
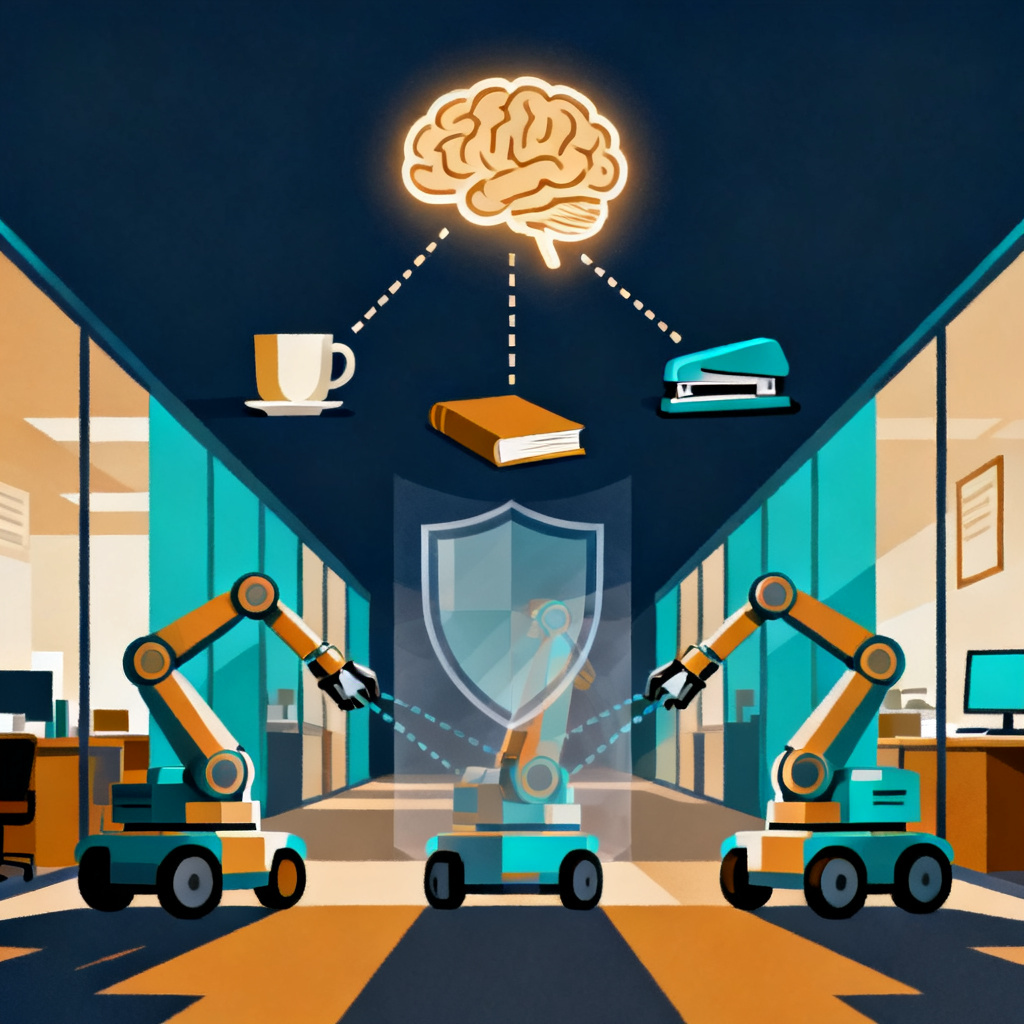
A fleet of three wheeled robot arms in an office hallway, each reaching toward different objects (a cup, a book, a stapler). Above them, a glowing brain icon connected by dashed lines to each robot. Between the brain and robots, a translucent shield icon filters the task descriptions.
AutoRT: Embodied Foundation Models for Large Scale Orchestration
Uses an LLM to propose diverse tasks filtered by safety, enabling large-scale real-world robot data collection in offices.
What changed
ModelBefore AutoRT, robot data collection required hand-scripting each task or narrow teleoperation, limiting diversity and scale. This paper showed that an LLM could autonomously propose varied, safe tasks for fleets of mobile manipulators, collecting thousands of demonstrations with minimal human oversight.
So what, in plain English
ModelAutoRT lets robots decide what to practice on their own, like a coach giving a team of athletes different drills chosen by a smart assistant that also checks no one gets hurt. This means robots can learn many new skills from real-world experience without a person having to program every single move.
Contribution to industry
ModelAutoRT established the fleet-scale, LLM-directed data collection loop now used by several robotics companies to gather diverse real-world demonstrations without manual task scripting. Its safety filtering pattern has been adopted in subsequent autonomy stacks, reducing deployment risk in semi-structured environments like offices and warehouses.
Typed judgments
Jev★★★★☆ robots · Physical AI 97%
Real hardware 89% · Open code / data 16% · Foundation-model based 93% · Survey / benchmark-only 5%
Probabilities from TypeSafe Jev over the title, venue and abstract; the filters on the atlas apply code-owned thresholds to these numbers.
Editor's notes
Summary. Uses an LLM to propose diverse tasks for fleets of mobile manipulators, filters every proposal through a safety layer, and collects the resulting real-world demonstrations in offices with minimal human supervision.
Industry. Established the fleet-scale, LLM-directed collection loop and safety filtering pattern industry now uses to gather large robot datasets without scripting each task by hand.