ModelBriefs · DeepSeek-V4-Flash · Graphics · Seedream-4.0
← Labs / 16
Research lab1 paper · 2020 · 1 source index
autonomymotion planningsafety
Official research archive↗Waymo Research
Primary publication program grounded in large-scale deployed autonomous driving and safety measurement.
No.Paper · what it does and showsIndustry contribution
01
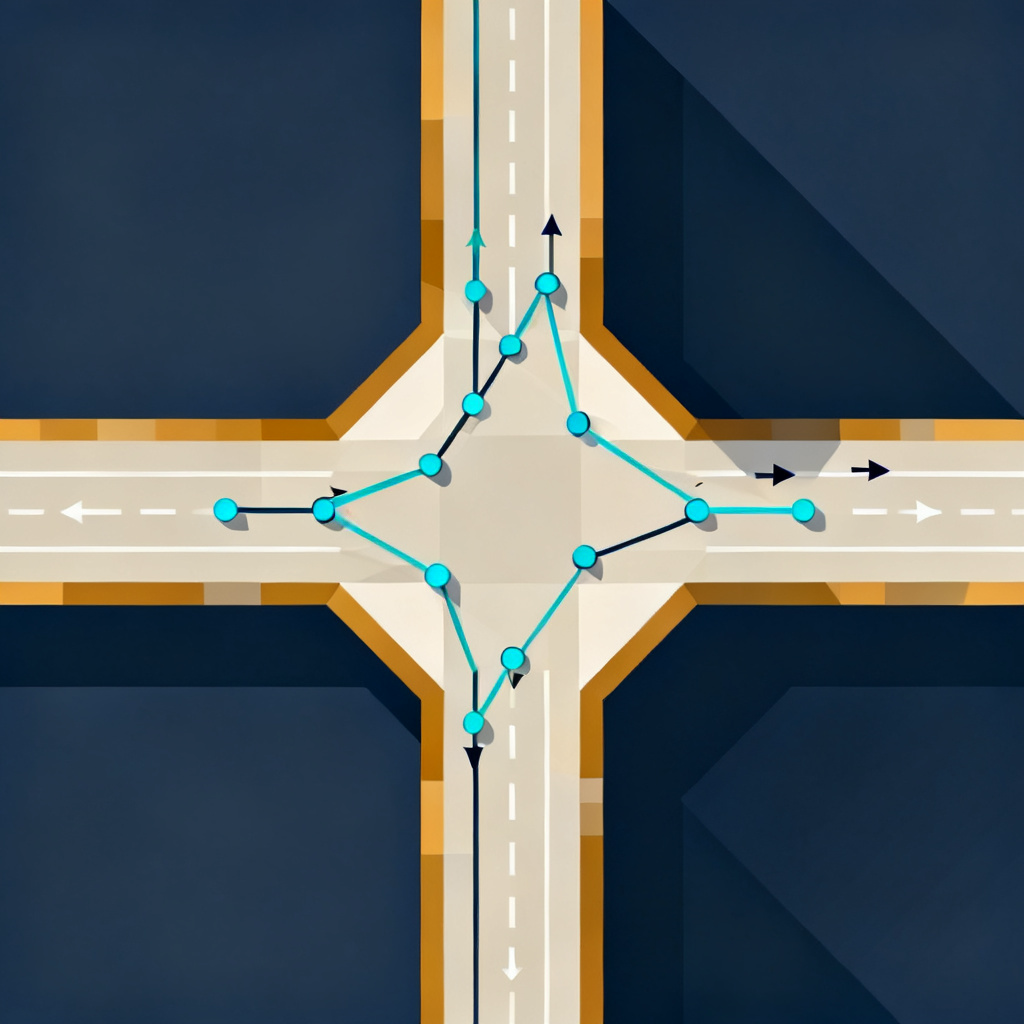
VectorNet: Encoding HD Maps and Agent Dynamics from Vectorized Representation2020 ↗
Encodes HD map elements and agent trajectories as vectorized graph nodes processed by a graph neural network, replacing rasterized image stacks for motion prediction.
Became a standard trajectory-prediction representation in autonomous driving and mobile robotics stacks, cutting compute while improving prediction accuracy.
—
Waymo Research PublicationsSource index
Not a single paper: Waymo’s official research archive of safety, planning, perception and simulation publications from its deployed autonomous driving programme.
Not a single paper, so no industry contribution is recorded.