Illustration brief the model wrote
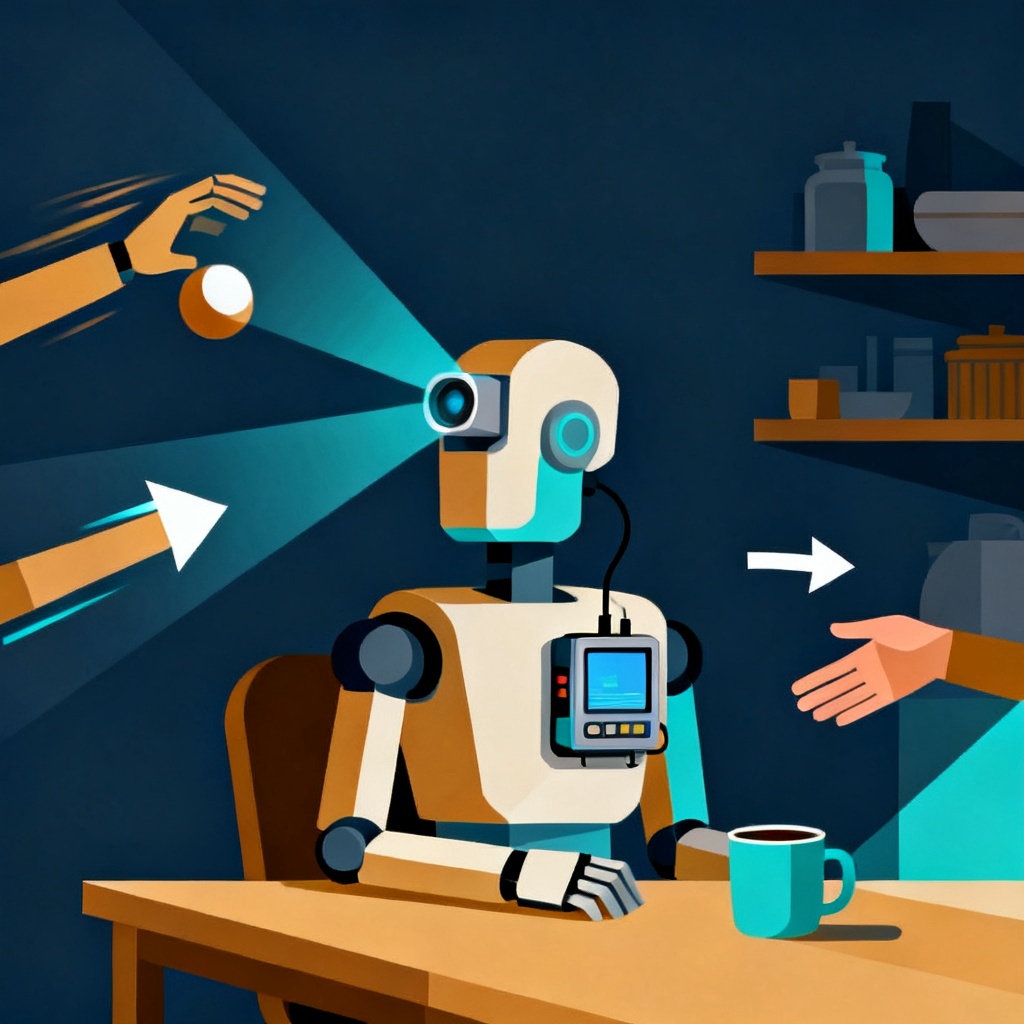
A humanoid robot torso at a table. A beam from its head camera hits a small onboard computer on its back. Two arrows emerge: one fast to an arm catching a ball, one slow to a hand reaching for a cup. Background shelves and household items.
Helix: A Vision-Language-Action Model for Generalist Humanoid Control
A single VLA controls a humanoid's upper body from pixels via dual-rate system on onboard hardware.
What changed
ModelPreviously, humanoid control either required high-end compute or separated reasoning from motor reflexes. Helix shows a single model running onboard on consumer-grade hardware, achieving fast visuomotor reflexes alongside slower reasoning, enabling generalist control in commercial pilots.
So what, in plain English
ModelHelix lets a humanoid robot handle both fast reflexes (like dodging a thrown object) and careful reasoning (like opening a door) using one system that runs on a regular computer. This means humanoid robots can work in real-world homes and factories without expensive, bulky hardware.
Contribution to industry
ModelHelix is deployed in commercial pilots by Figure AI, demonstrating that generalist humanoid control is feasible on consumer-grade onboard compute. This reduces cost and power requirements, accelerating potential adoption in logistics, manufacturing, and household assistance.
Typed judgments
Jev★★★★☆ robots · Physical AI 97%
Real hardware 83% · Open code / data 8% · Foundation-model based 91% · Survey / benchmark-only 3%
Probabilities from TypeSafe Jev over the title, venue and abstract; the filters on the atlas apply code-owned thresholds to these numbers.
Editor's notes
Summary. A single VLA that controls the humanoid’s upper body from pixels using a dual-rate system: fast visuomotor reflexes at high frequency plus a slower reasoning VLM, all running on onboard hardware.
Industry. One of the first humanoid VLAs running onboard in commercial pilots, showing generalist humanoid control can live on consumer-grade compute.