ModelBriefs · DeepSeek-V4-Flash · Graphics · Seedream-4.0
← Labs / 02
Research lab1 paper · 2022 · 1 source index
language-conditioned roboticsembodied AIaffordance grounding
Official projects index (Physical AI filtered)↗Google Research
Official projects index filtered to Physical AI: PaLM-SayCan grounded a large language model in real robot affordances on Everyday Robots hardware.
No.Paper · what it does and showsIndustry contribution
01
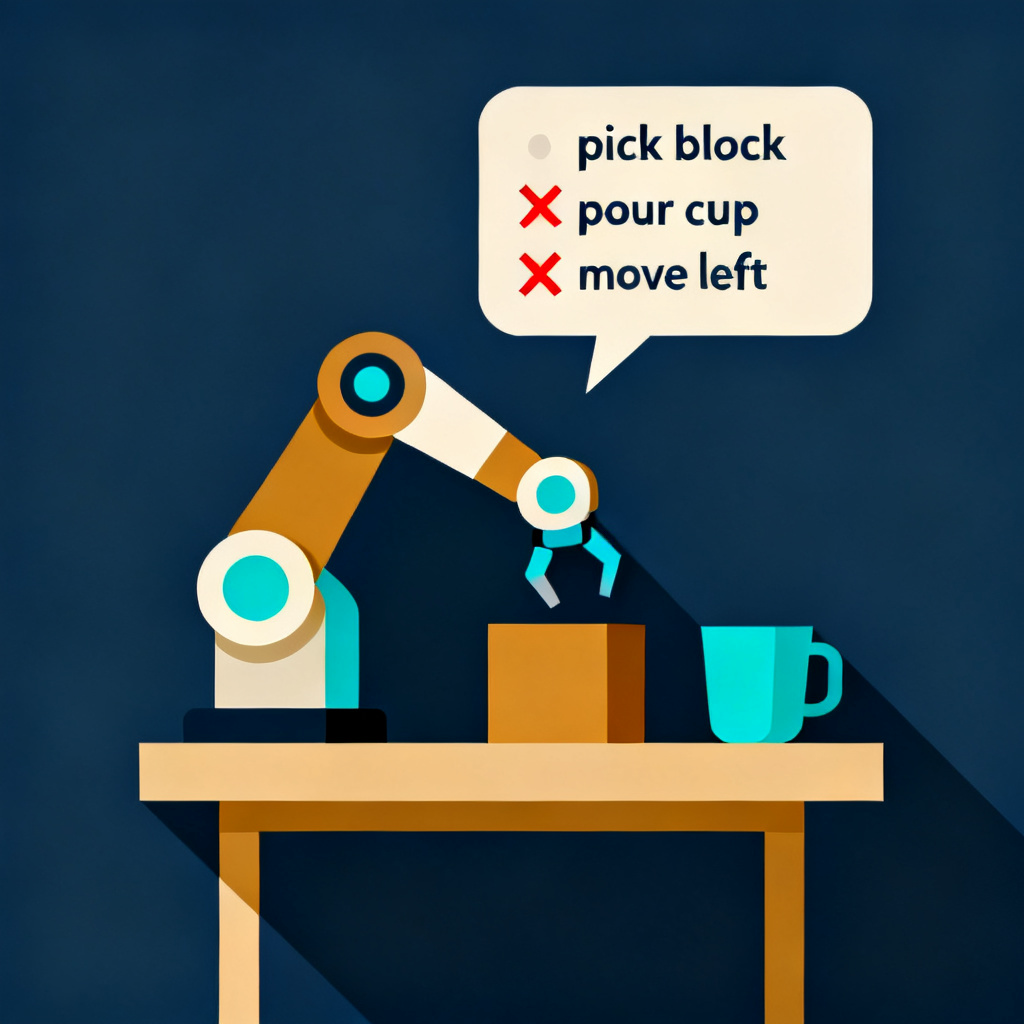
Do As I Can, Not As I Say: Grounding Language in Robotic Affordances2022 ↗
Grounds large language model plans in a robot’s learned affordances so the model proposes steps and the robot scores and executes only the ones it can actually do, replanning when a step fails.
Established the "LLM reasons, robot filters" pattern industry uses to turn natural-language instructions into safe, executable robot actions on factory and service floors.
—
PaLM-SayCan project pageSource index
Not a single paper: the official project page collecting the SayCan papers, videos and Everyday Robots demonstrations that grounded language-model planning in real robot affordances.
Not a single paper, so no industry contribution is recorded.